Microcontrollers like an Arduino or an STM32 are excellent for logic, but they lack the current-carrying capacity to drive heavy loads, such as motors, directly. Ever fried a driver chip because you underestimated a motor’s back-EMF spike? You’re not alone, and the L298N is the industry-standard fix for exactly that problem.
Before diving into the specs, it’s worth naming the real problem. Sourcing accurate models for a chip like this eats hours you don’t have, and a mismatch between your layout and logic files can send a bad board straight to fabrication. Getting the datasheet details right up front is the difference between a clean build and an expensive redo.
Produced by STMicroelectronics, this dual H-bridge high-current motor driver can control the speed and direction of two DC motors or one stepper motor. This guide breaks down the L298N datasheet to show the technical specifications, physical pinout, and practical application requirements for this versatile IC.
What is the L298N?
Think of the L298N as a translator. It takes the low-current logic signal from your microcontroller and converts it into the higher-voltage, higher-current output a motor requires.
The L298N is a high-voltage, high-current dual full-bridge driver designed to accept standard Transistor-Transistor Logic (TTL) levels. It drives inductive loads such as:
- Relays, solenoids
- DC motors
- Both unipolar and bipolar stepper motors.
More specifically, the L298N driver contains two H-bridge circuits, each of which allows current to flow through a motor (or coil) in either direction, enabling bidirectional control.
L298N Datasheet Specifications
Exceeding the operating limits specified in the L298N datasheet can cause immediate silicon failure.
Absolute maximum ratings
| Parameter | Value |
| Power supply | 50 V |
| Logic supply voltage | 7 V |
| Input and enable voltage | –0.3 V to 7 V |
| Peak output current (each channel): • Non repetitive (t = 100 ms) • Repetitive (80% on –20% off; ton = 10 ms) • DC operation | 3 A 2.5 A 2 A |
| Sensing voltage | –1 V to 2.3 V |
| Total power dissipation (tcase = 75 °C) | 25 W |
| Junction operating temperature | –25 °C to 130 °C |
| Storage and junction temperature | –40 °C to 150 °C |
Technical Note: Voltage Drop
One critical detail often overlooked is the voltage drop across the output stage. Because the L298N uses bipolar transistors rather than Metal-Oxide-Semiconductor Field-Effect Transistors (MOSFETs), there is a cumulative drop of about 1.5 V to 2.5 V between the supply voltage (Vs) and the motor terminals. This must be accounted for in your power budget.
Pinout and Functional Descriptions
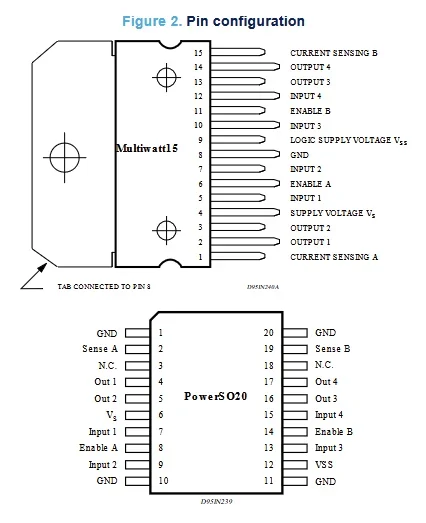
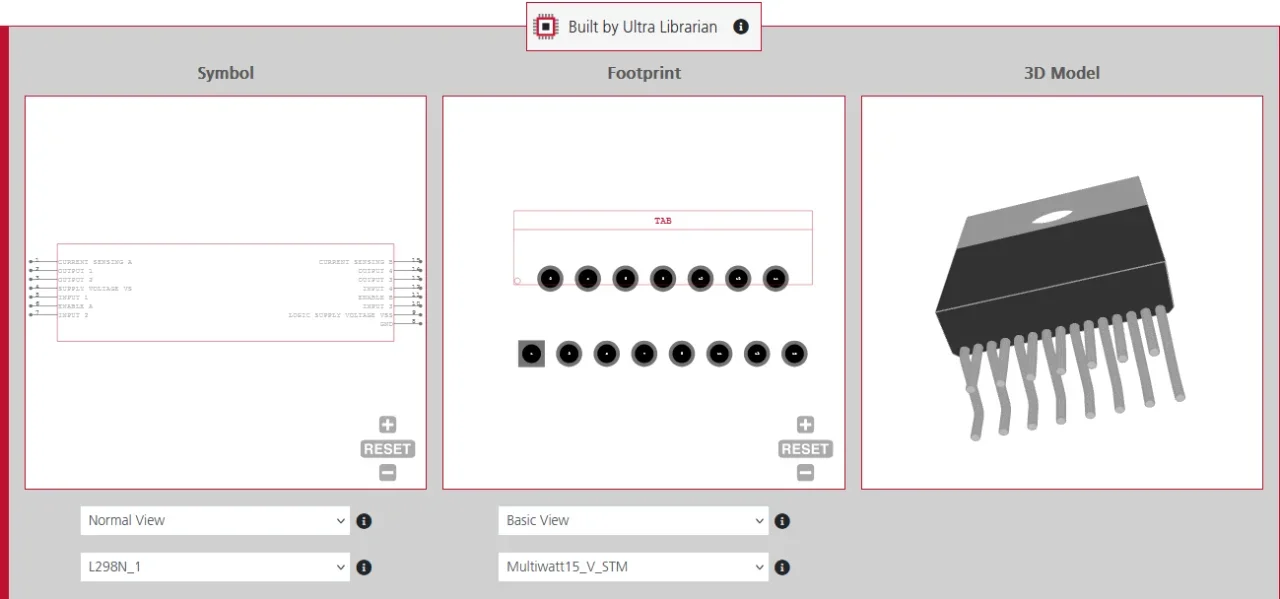
The L298N is manufactured in two primary packages: the Multiwatt15 (through-hole version) and the PowerSO20 (surface mount version). While pin numbering varies by package, the functional groups remain the same:
- Outputs (OUT1 through OUT4): These pins connect directly to the motor terminals. OUT1 and OUT2 serve Bridge A, while OUT3 and OUT4 serve Bridge B.
- Logic Inputs (IN1 through IN4): These accept TTL signals from the Microcontroller Unit (MCU) to control the bridge state. For a DC motor, setting one input HIGH and the other LOW sets the direction.
- Enable Pins (ENA, ENB): These act as the “on/off” switch for each bridge. In most designs, a Pulse Width Modulation (PWM) signal is applied to these pins to control the motor speed.
- Current Sensing (SENS A, SENS B): These pins are located at the bottom of each H-bridge. They allow connecting an external sensing resistor to ground to monitor motor current. If current sensing is not needed, these pins must be tied directly to ground.
- Supply Pins (Vs, Vss): The Vs pin provides high-voltage power to the motors, while Vss provides 5 V logic power to the internal circuitry.
- Ground (GND): This is the common ground reference for both the high-power motor supply and the low-power logic supply.
Package Comparison: Multiwatt15 vs. PowerSO20
| Feature | Multiwatt15 | PowerSO20 |
| Mounting Style | Through-Hole (Vertical) | Surface Mount (SMD) |
| Total Pins | 15 | 20 |
| Cooling Method | External Bolt-on Heatsink | PCB Copper Pour / Thermal Vias |
| Best Used For | High-power, high-heat apps | Compact, automated SMT assembly |
| GND Connection | Single Pin (Pin 8) | Multiple pins connected to a thermal slug |
The Multiwatt15 remains the standard for high-power motor control due to its superior ease of cooling, while the PowerSO20 is better suited to compact designs. If your Printed Circuit Board (PCB) layout uses the Surface Mount Technology (SMT) version, ensure the thermal pad is correctly defined in your Computer-Aided Design (CAD) library to prevent the chip from overheating during operation.
Getting that thermal pad definition wrong is a common (and costly) source of manufacturing errors. Ultra Librarian’s verified PowerSO20 footprint takes that guesswork off your plate.
Motor Control Wiring Basics
To drive a DC motor, connect the motor to OUT1 and OUT2. The logic follows this pattern:
- Forward: IN1 = High, IN2 = Low
- Reverse: IN1 = Low, IN2 = High
- Brake: IN1 = High, IN2 = High (or Low/Low)
Stepper Motor Control
To drive a bipolar stepper motor, connect the motor’s two coils to Bridge A (OUT1/OUT2) and Bridge B (OUT3/OUT4). The MCU must step through a specific logic sequence on IN1 through IN4 to rotate the motor.
Practical Implementation Notes
Heat Dissipation
Push this chip toward its rated current, and it runs hot. A large heatsink is mandatory here, as it’s considered to be the price of admission. The datasheet indicates a large heatsink is mandatory for high-current applications. Without thermal management, the chip’s internal protection will trigger, or the part will suffer permanent damage.
External Diodes
Cut the power to a motor mid-spin, and the coil fights back since that stored energy ends up with nowhere to go. Unlike some modern drivers, the L298N doesn’t have internal freewheeling diodes to absorb that energy. That means when the motor stops, it generates an inductive spike (back-EMF).
As a result, you need to place eight fast-recovery diodes (like the 1N5819 Schottky) on your PCB to protect the driver from these spikes. Sourcing the right diode footprint and confirming it actually matches your fab’s specs are exactly the kind of busywork Ultra Librarian’s verified CAD models take off your hands.
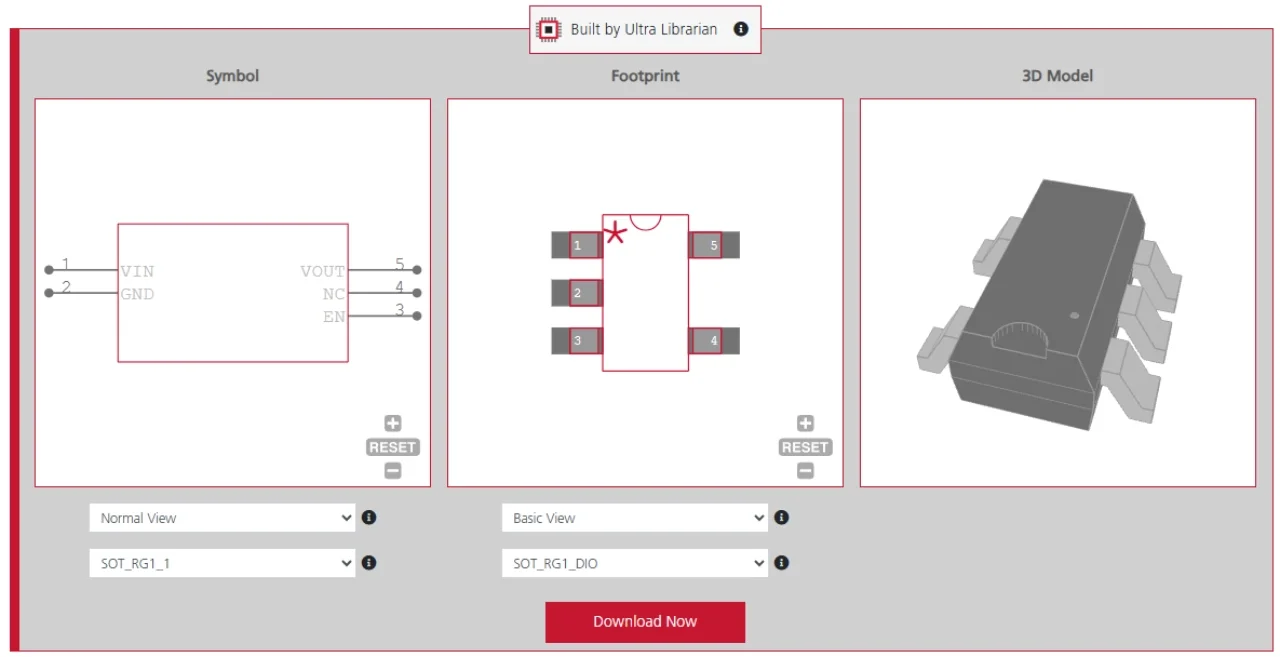
 If you’re looking for any of our component footprints or models, we have readily available and free options for you and your design team. Search our library for the solution you’ve been looking for.